01TDX 2025
In the lab, we learn them inside and out.
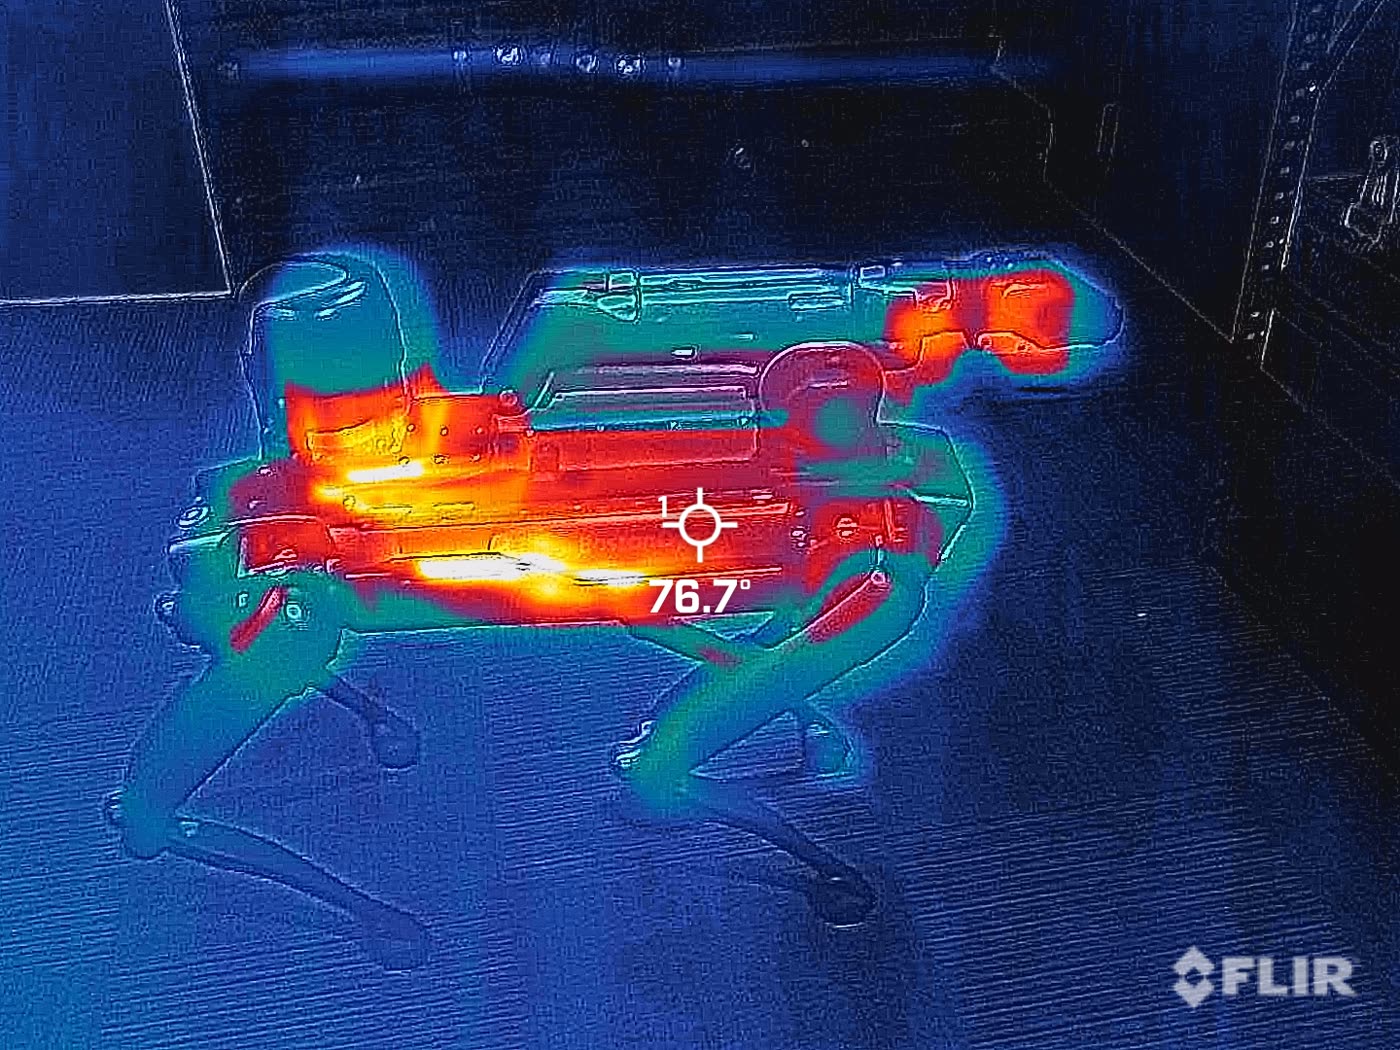
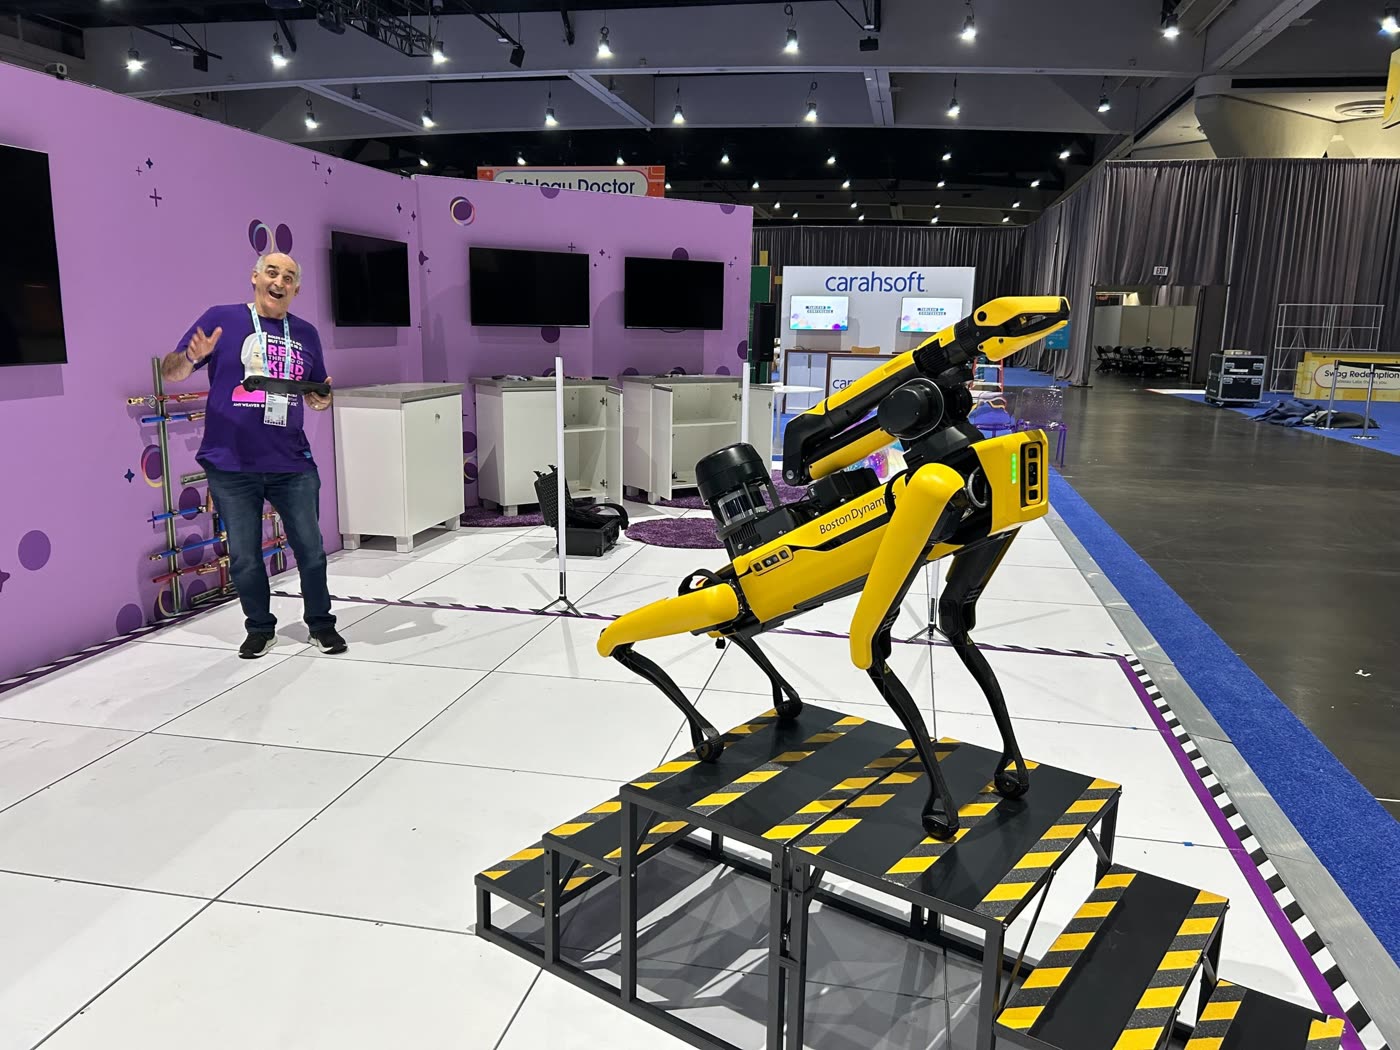
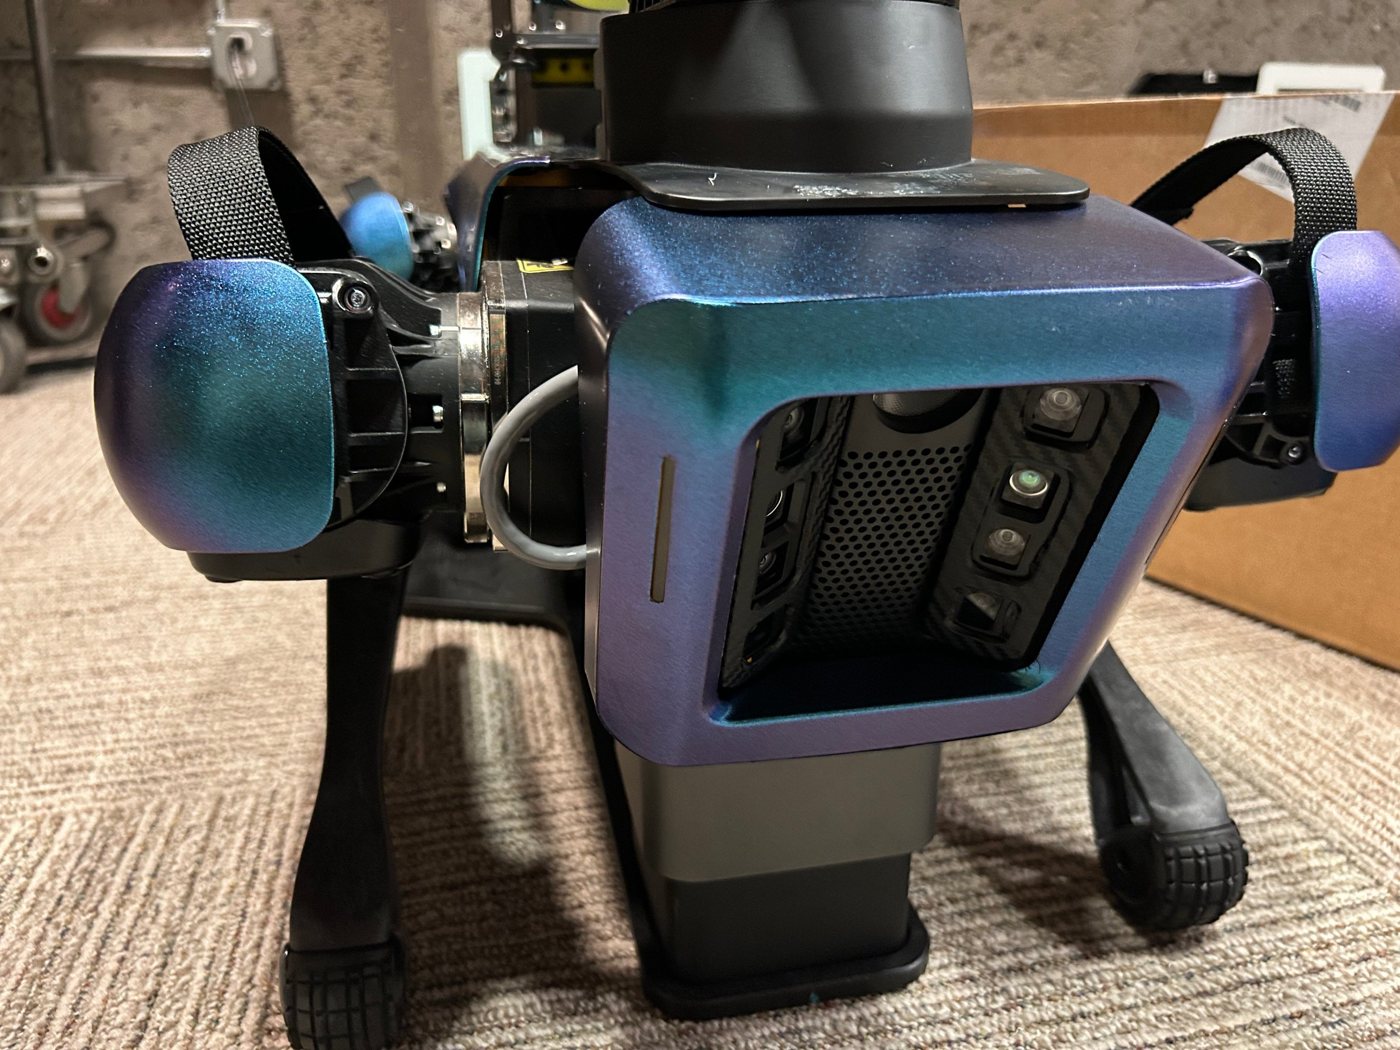
Before any agent touched a robot, we got to know the hardware. We wrote every motion by hand and tuned it until it was repeatable, and we studied each machine from the outside in: how it moves, where it fails, and how hot it runs.
At TDX, our Unitree humanoids ran on dead reckoning: counted steps and timed turns, with no way to check where they actually ended up. It was all their APIs supported at the time. We're not proud of it, and it's a big part of why our hand-written versions were less reliable than what came later.